
Languages: English | 简体中文


UniSuperMimic is an independent downstream reproduction of SuperMimic on UniLab for Unitree G1 whole-body tracking of LAFAN1 motions, with mjwarp, MuJoCo, and Motrix backends. It includes a differentiable world model, a goal-conditioned policy, a Manager-Based task, tools for 40 motion assets, and entry points for training and deterministic full-library evaluation.
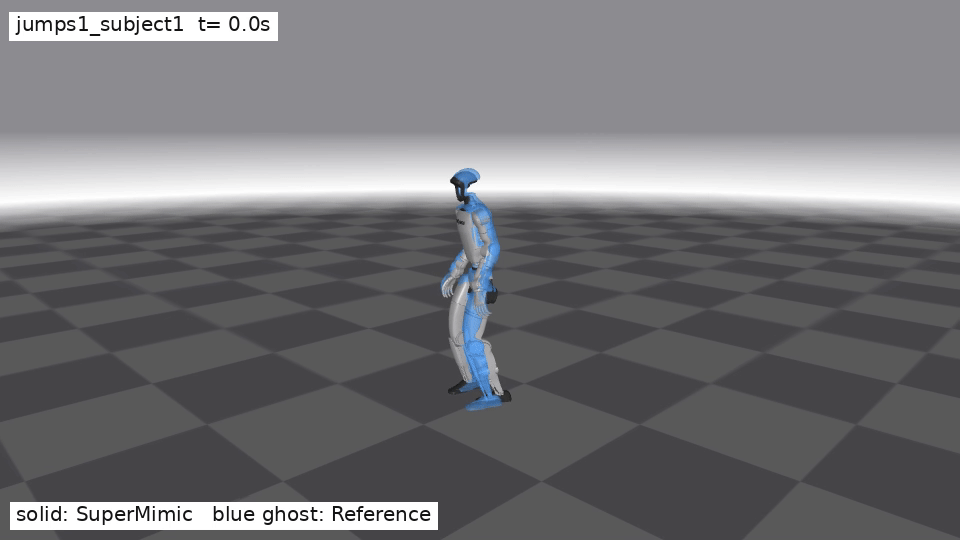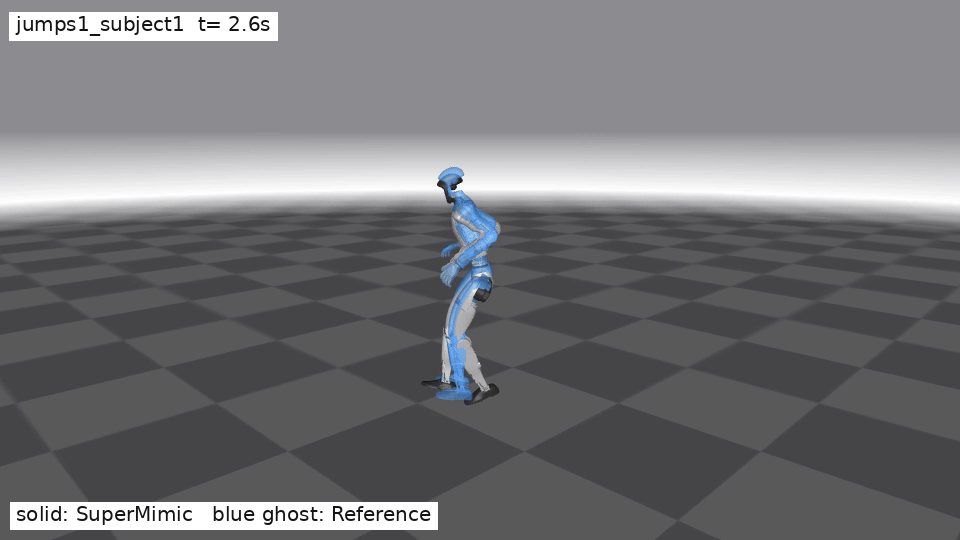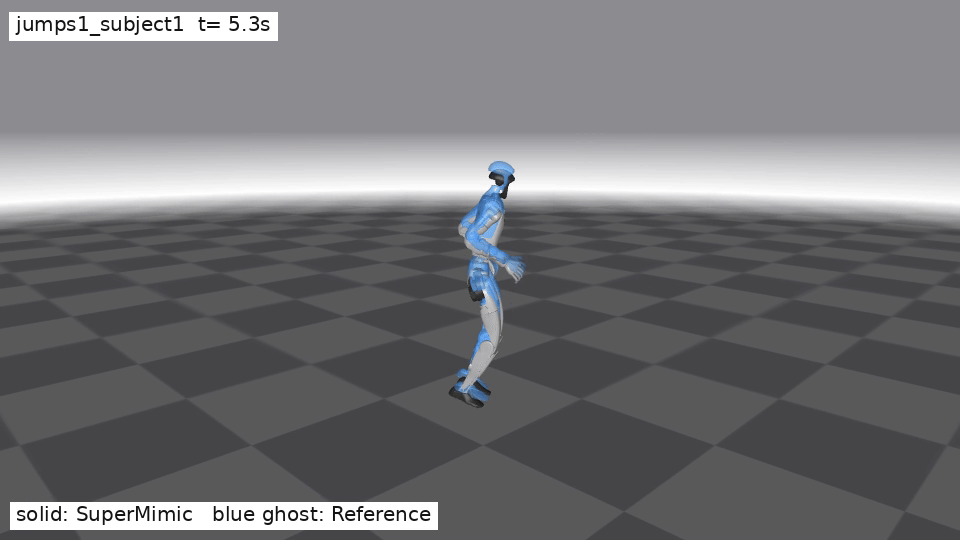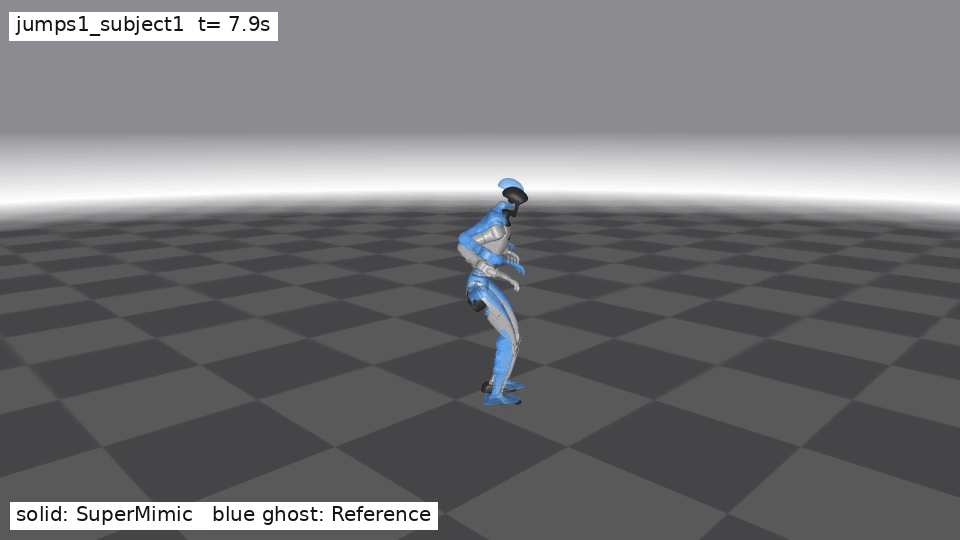
Solid robot: SuperMimic policy. Blue ghost: reference motion. Click the image to view the MP4.
Paper: SuperMimic: Scaling Humanoid Whole-Body Control with One Differentiable World Model, Qiayuan Liao et al. The implementation references supermimic_vibed and depends on PyPI unilab.
unisupermimic/
├── src/unisupermimic/
│   ├── rl/
│   │   ├── algos/supermimic/       # World model, policy, critic, replay, and learner
│   │   └── contracts/supermimic.py # Environment/algorithm tensor contract
│   ├── tasks/motion_tracking/g1/supermimic/
│   │   ├── env.py                  # Manager-Based environment and backend factory
│   │   ├── manager_terms.py        # Command/action/observation/event/reward terms
│   │   ├── motion.py, mdp.py       # Motion library and differentiable MDP
│   │   ├── evaluate.py             # Deterministic full-clip evaluation from frame zero
│   │   ├── render.py               # Policy rollout and reference-motion comparison video
│   │   └── registry.py             # G1SuperMimic registration
│   ├── scripts/train_supermimic.py # Training, resume, and evaluation entry point
│   ├── conf/supermimic/            # Hydra configuration
│   ├── assets/robots/g1/           # G1 MJCF; meshes/URDF are downloaded and untracked
│   ├── assets/motions/             # LAFAN1 CSV files, downloaded and untracked
│   └── sim2sim.py                  # Policy I/O, network shape, and asset identity checks
├── docs/assets/                    # Result curves, MP4, and GIF
├── tools/prepare_supermimic_assets.py
├── tests/
├── pyproject.toml, uv.lock
├── LICENSE, LICENSES/, NOTICE
└── Makefile
Requirements: Linux, Python 3.10–3.13, and uv. A CUDA GPU is required for mjwarp training. Run all commands from the repository root. uv run uses uv.lock to synchronize the project, PyPI unilab, all three simulation backends, and development dependencies.
uv run unisupermimic-train --helpRun uv lock after changing dependencies.
On AMD ROCm hosts, install from the pre-resolved ROCm lockfile instead (a ROCm PyTorch build with the same pinned dependency set):
make sync-rocmCUDA-only backends (mjwarp) stay unsupported there; train with the MuJoCo
host-bridge backend (task=g1_super_mimic/mujoco). make sync-rocm swaps
pyproject.toml/uv.lock for the ROCm profile; run make sync-default to
switch back. Maintainers regenerate the ROCm lockfile after dependency changes
with make lock-rocm.
# Download LAFAN1/G1 data from Hugging Face, then generate and validate MJCF.
uv run tools/prepare_supermimic_assets.py

# Validate existing assets offline.
uv run tools/prepare_supermimic_assets.py --validate-only
Assets come from lvhaidong/LAFAN1_Retargeting_Dataset. A complete asset set contains 40 CSV files with 264,705 source frames and 36 columns per frame. Meshes, URDF, CSV files, logs, and checkpoints are excluded by .gitignore.
Run the following commands from the repository root and set CUDA_VISIBLE_DEVICES to an available GPU when using CUDA.
# Default: mjwarp, 4096 parallel environments, 12000 iterations.
CUDA_VISIBLE_DEVICES=0 uv run unisupermimic-train \
  training.log_dir=runs/supermimic_mjwarp_001

# Resume from last.pt in the same run and train to 16000 iterations.
CUDA_VISIBLE_DEVICES=0 uv run unisupermimic-train \
  algo.resume=true \
  algo.load_run=runs/supermimic_mjwarp_001 \
  algo.checkpoint=last.pt \
  algo.iterations=16000

# Select MuJoCo through the task owner.
uv run unisupermimic-train \
  task=g1_super_mimic/mujoco \
  training.log_dir=runs/supermimic_mujoco_001

# Select Motrix through the task owner.
uv run unisupermimic-train \
  task=g1_super_mimic/motrix \
  training.log_dir=runs/supermimic_motrix_001
Use the same task=g1_super_mimic/<backend> override when resuming or evaluating a MuJoCo or Motrix run. Motrix uses fixed friction; center-of-mass and joint-offset domain randomization remain enabled. Use Hydra syntax for other configuration overrides. For a quick smoke run, override options such as algo.num_envs, algo.iterations, algo.wm_hidden, algo.policy_hidden, and algo.compile=false. See src/unisupermimic/conf/supermimic/config.yaml for the complete default configuration.
Evaluation creates one environment per motion, starts from its first frame, disables observation and action noise, and runs the complete clip. Strict sim2sim validation checks policy I/O, network shape, motion library, and MJCF identity before environment construction.
CUDA_VISIBLE_DEVICES=0 uv run unisupermimic-train \
  training.play_only=true \
  algo.load_run=runs/supermimic_mjwarp_001 \
  algo.checkpoint=12000
Results are written to ckpt_012000_eval.json in the same directory. You can also evaluate a checkpoint directly. The standalone evaluator and video exporter accept --backend mjwarp, --backend mujoco, or --backend motrix and default to mjwarp:
CUDA_VISIBLE_DEVICES=0 uv run unisupermimic-eval \
  --backend mjwarp \
--ckpt runs/supermimic_mjwarp_001/ckpt_012000.ptThe following command rolls out jumps1_subject1 continuously from a checkpoint, trims the result to the jumping segment from 6–14 seconds, and writes a 25 fps comparison MP4:
CUDA_VISIBLE_DEVICES=0 MUJOCO_GL=egl uv run unisupermimic-video \
  --backend mjwarp \
  --ckpt runs/supermimic_mjwarp_001/ckpt_012000.pt \
  --clip jumps1_subject1 \
  --start 6 \
  --seconds 8 \
  --output docs/assets/supermimic_comparison.mp4
By default, the reference root XY is aligned with the policy to highlight whole-body tracking. Pass --global-ghost to preserve the reference motion's global displacement.
Configuration: PyPI unilab 1.5.0, mjwarp, and 4096 training environments. Evaluation covers 40 LAFAN1/G1 motions. norm_return is the macro average across clips; frame-weighted is weighted by clip length.
| checkpoint | norm_return | frame-weighted | failed clips |
|---|---|---|---|
| ckpt_012000.pt | 0.827227 | 0.829952 | 0 / 40 |

make check       # ruff, mypy, pyright
make test        # Non-slow tests
make test-all    # Include production backend slow tests; mjwarp requires CUDA
uv run tools/prepare_supermimic_assets.py --validate-onlyThe repository code is released under Apache-2.0. The reference implementation's MIT license and original copyright notice are preserved in LICENSES/MIT-supermimic.txt; see also NOTICE. UniLab, UniSim, MuJoCo/mjwarp, MotrixSim, and the datasets retain their respective upstream licenses. This repository does not relicense those external dependencies or downloaded assets.